

Nvidia & Hugging Face to Collaborate on Open-Source Robotics Models
NVIDIA and Hugging Face have expanded their collaboration to integrate NVIDIA's Isaac GR00T 1.7 reasoning vision-language-action model and Isaac Teleop framework into the LeRobot open-source robotics library, with NVIDIA Cosmos 3 planned for future integration. The partnership connects NVIDIA's 3 million robotics developers with Hugging Face's 16 million AI builders to lower barriers in physical AI development.
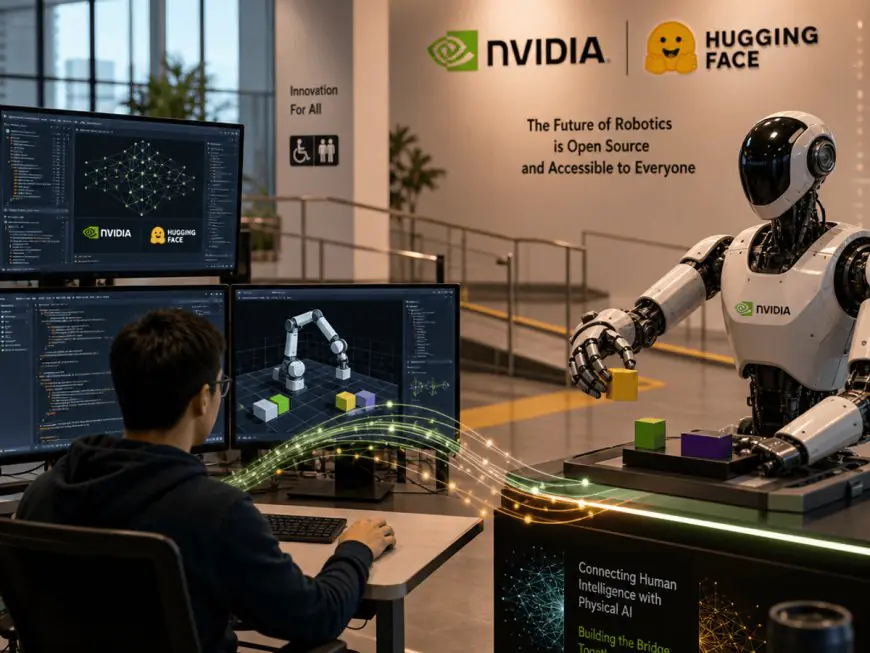
NVIDIA and Hugging Face have significantly expanded their collaboration to bring advanced robotics AI tools to the open-source community.

The partnership integrates NVIDIA Isaac GR00T 1.7, an open reasoning vision-language-action model for humanoid robots, and the NVIDIA Isaac Teleop framework into LeRobot, Hugging Face's open-source robotics library for training and sharing robot datasets, models, and policies.
The integration gives developers a standardized path for end-to-end robot development while driving innovation across the open robotics community.
Thomas Wolf, co-founder and chief science officer at Hugging Face, emphasized the importance of open-source collaboration: "Open source is how a field turns advanced research into something people can study, adapt and build on.
With NVIDIA Isaac GR00T 1.7 and Isaac TeleOp in LeRobot today, robotics developers can use shared models, data and workflows to train and evaluate robots in the open".
The partnership connects NVIDIA's 3 million robotics developers with Hugging Face's 16 million AI builders, expanding access to frontier physical AI tools through open workflows.
NVIDIA Isaac GR00T 1.7 is described as the first open and commercially viable robot foundation model, allowing developers to post-train and deploy models through LeRobot workflows while adapting to new robot embodiments and tasks with benchmarked performance.
The model features a dual-system architecture that separates high-level reasoning from low-level motor control, validated across loco-manipulation and dexterous bimanual tasks.
The open-source robotics ecosystem aims to address fragmentation in physical AI development, where progress has been gated by costly and disparate resources including large datasets, robot foundation models, simulation, compute, and validation tools.
By providing a unified framework for data collection, model training, performance evaluation, and deployment, NVIDIA and Hugging Face are working to significantly lower barriers to entry for robotics AI development.